Formotion Glove G7 Product Specifications
1. Product Overview
Forsense Glove G7 is designed for professional hand-motion capture, supports millimeter-level hand-motion reconstruction, and is suitable for high-precision dexterous-hand teleoperation and professional data collection.
2. Package Contents
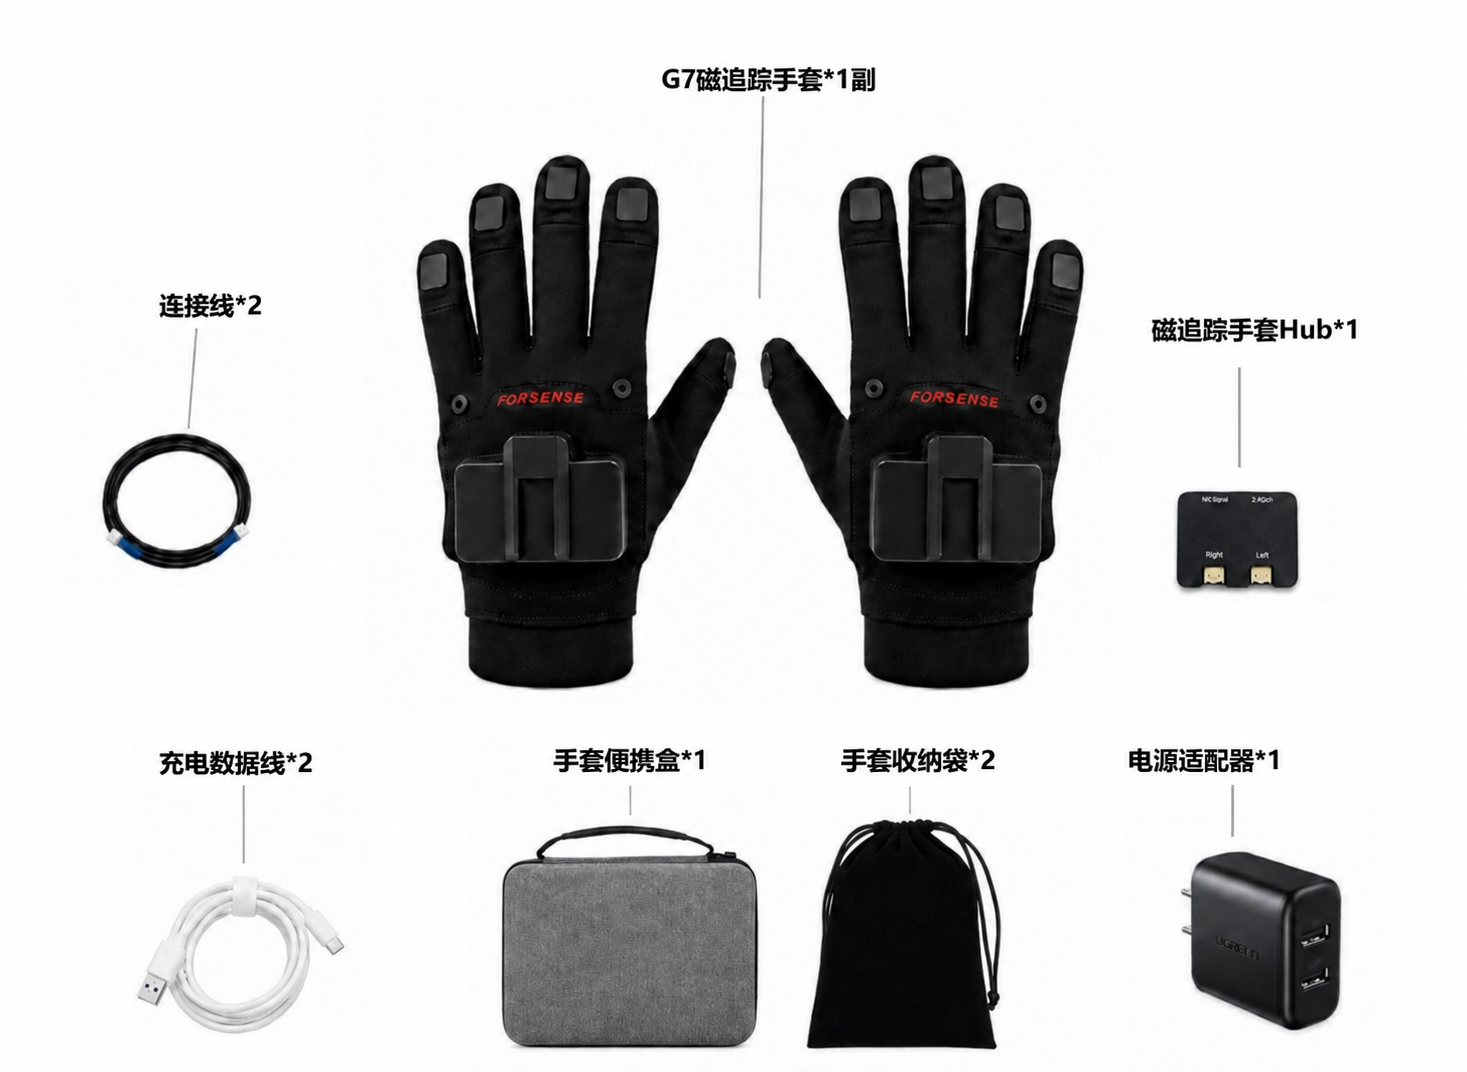
Standard
Optional
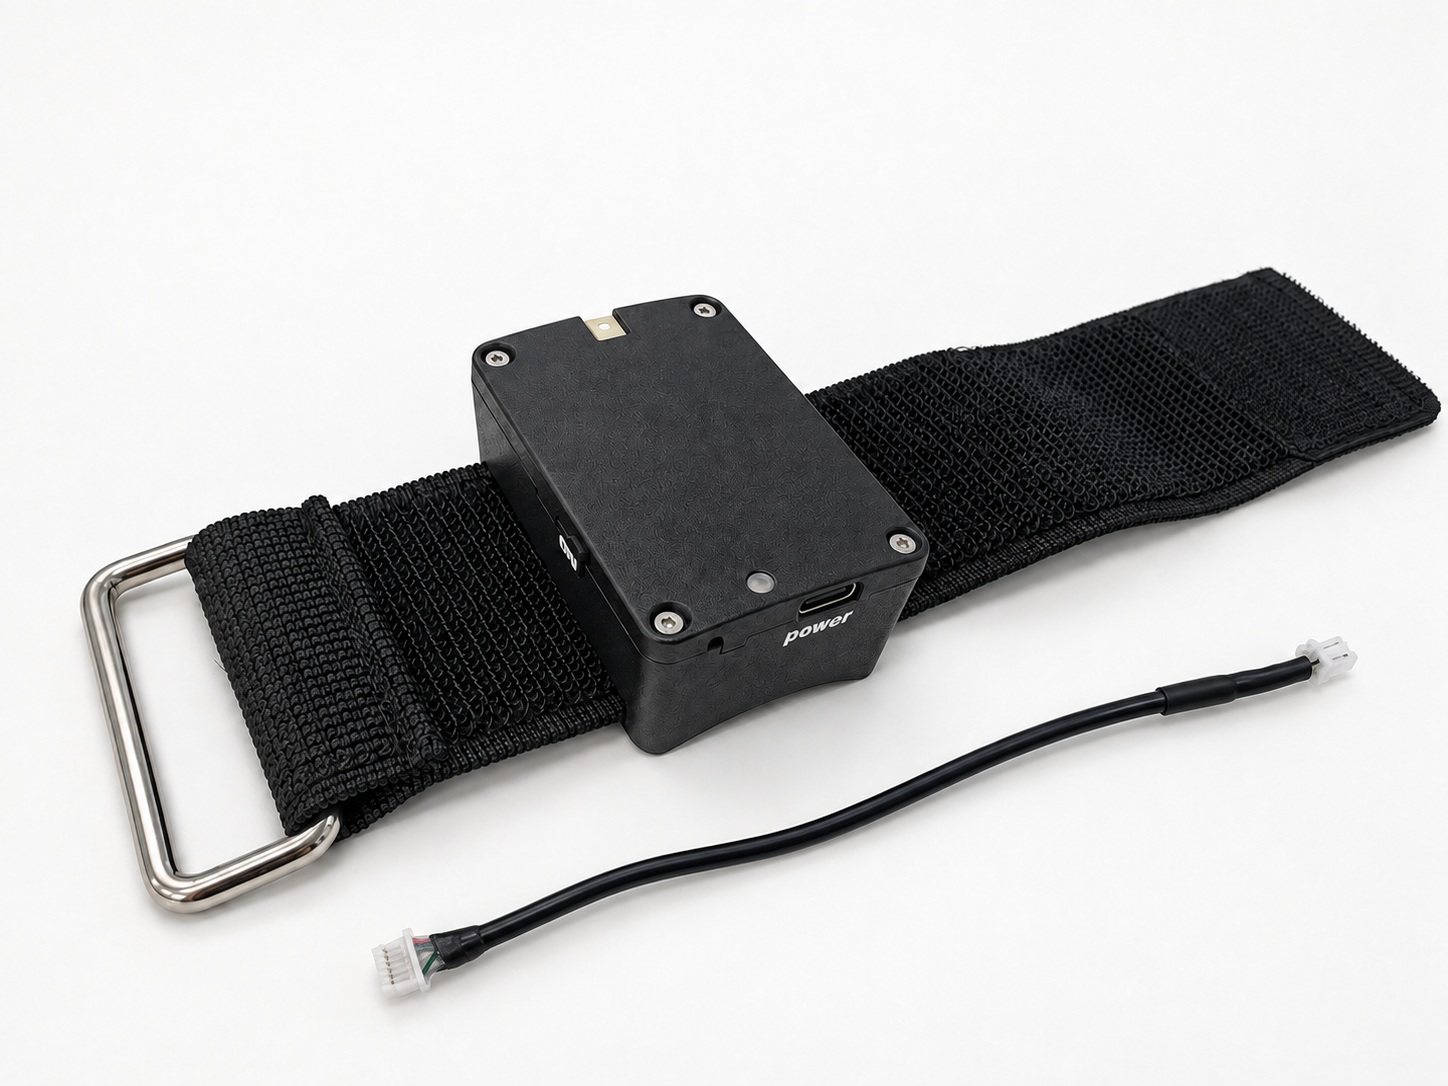
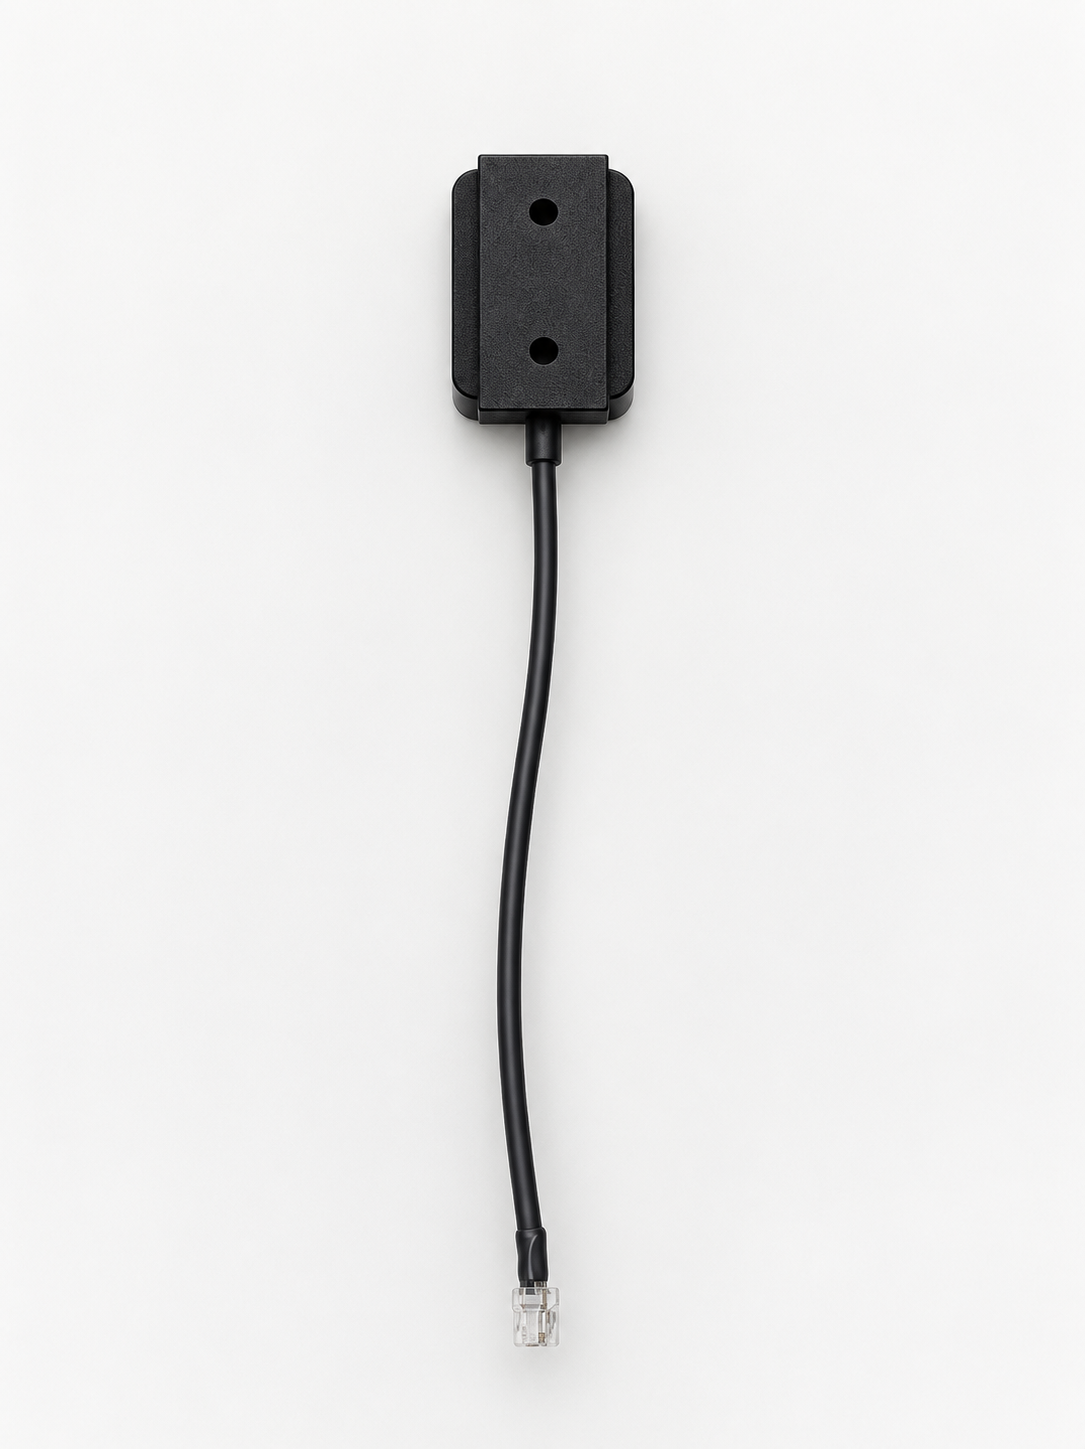
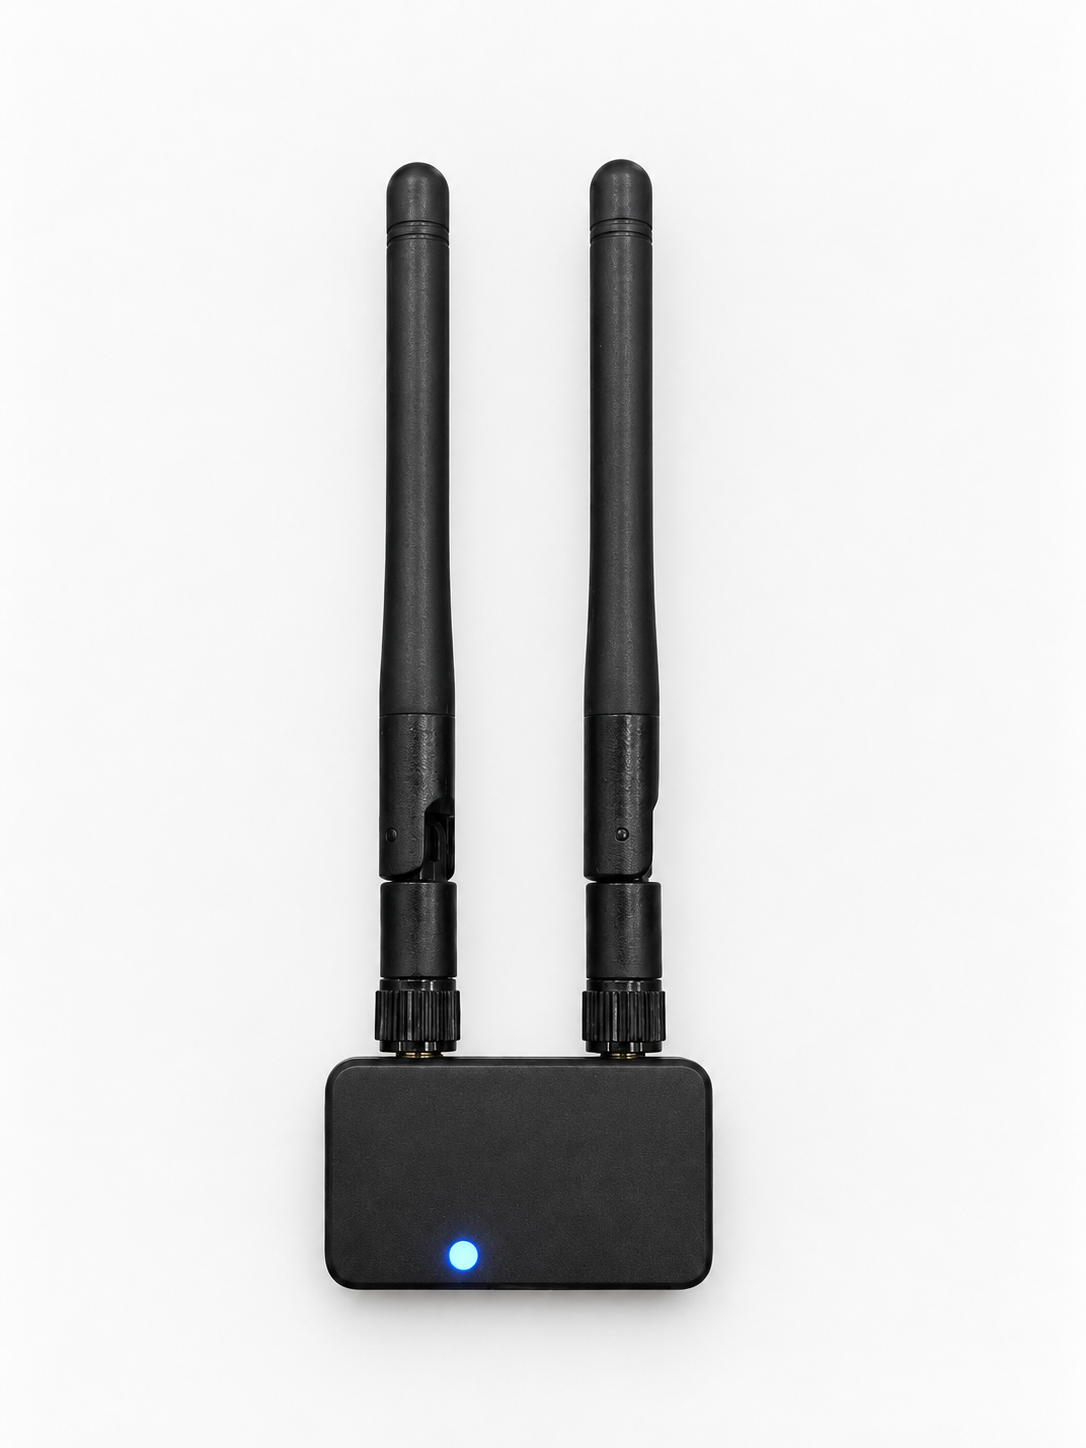
| ForMotion Glove G7 magnetic-tracking glove packing list | |||||
|---|---|---|---|---|---|
| No. | Item | Configuration | Remarks | Quantity | Unit |
| 1 | Sensor (one hand) | Standard | 5 fingertip magnetic-inertial modules (EMF+IMU), 1 dorsal IMU sensor | 1 | set |
| 2 | Dorsal controller (one hand) | Processing unit, 1 IMU sensor | 1 | pc | |
| 3 | G7 magnetic-tracking glove | G7 magnetic-tracking glove body | 1 | pair | |
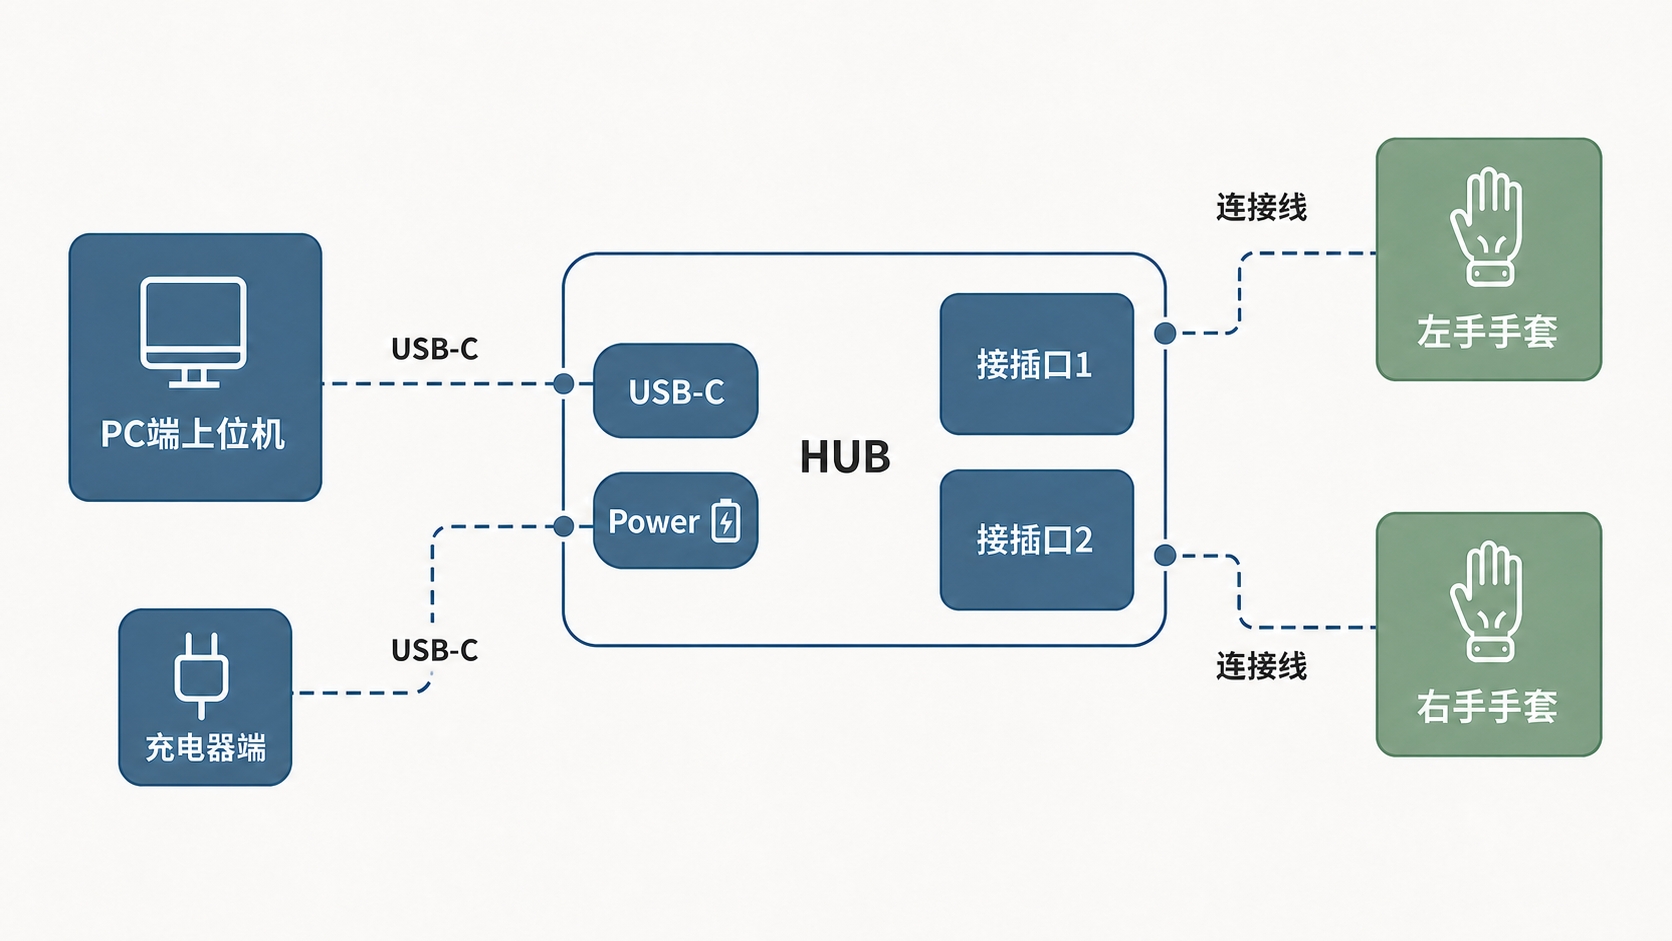
| 4 | G7 magnetic-tracking Hub | Connects both gloves and provides power, communication aggregation, and bimanual synchronization | 1 | pc | |
| 5 | Connection cable (1 m) | Connects the controller and Hub | 2 | pc | |
| 6 | Data cable (1 m) | Data communication and power for the glove controller | 2 | pc | |
| 7 | Storage case | Holds the gloves, data cables, Hub, and related hardware | 1 | pc | |
| 8 | Certificate of conformity | Product certificate of conformity | 1 | pc | |
| 9 | Quick start guide (electronic) | Product quick start guide | 1 | pc | |
| 10 | Power adapter | 5 V 3.4 A power adapter | 1 | pc | |
| 11 | Storage bag | Stores the gloves | 2 | pc | |
| 12 | Wireless module | Optional | Power and wireless transmission | 2 | pc |
| 13 | Forearm module | Adds a forearm node (with strap and cable harness) | 2 | pc | |
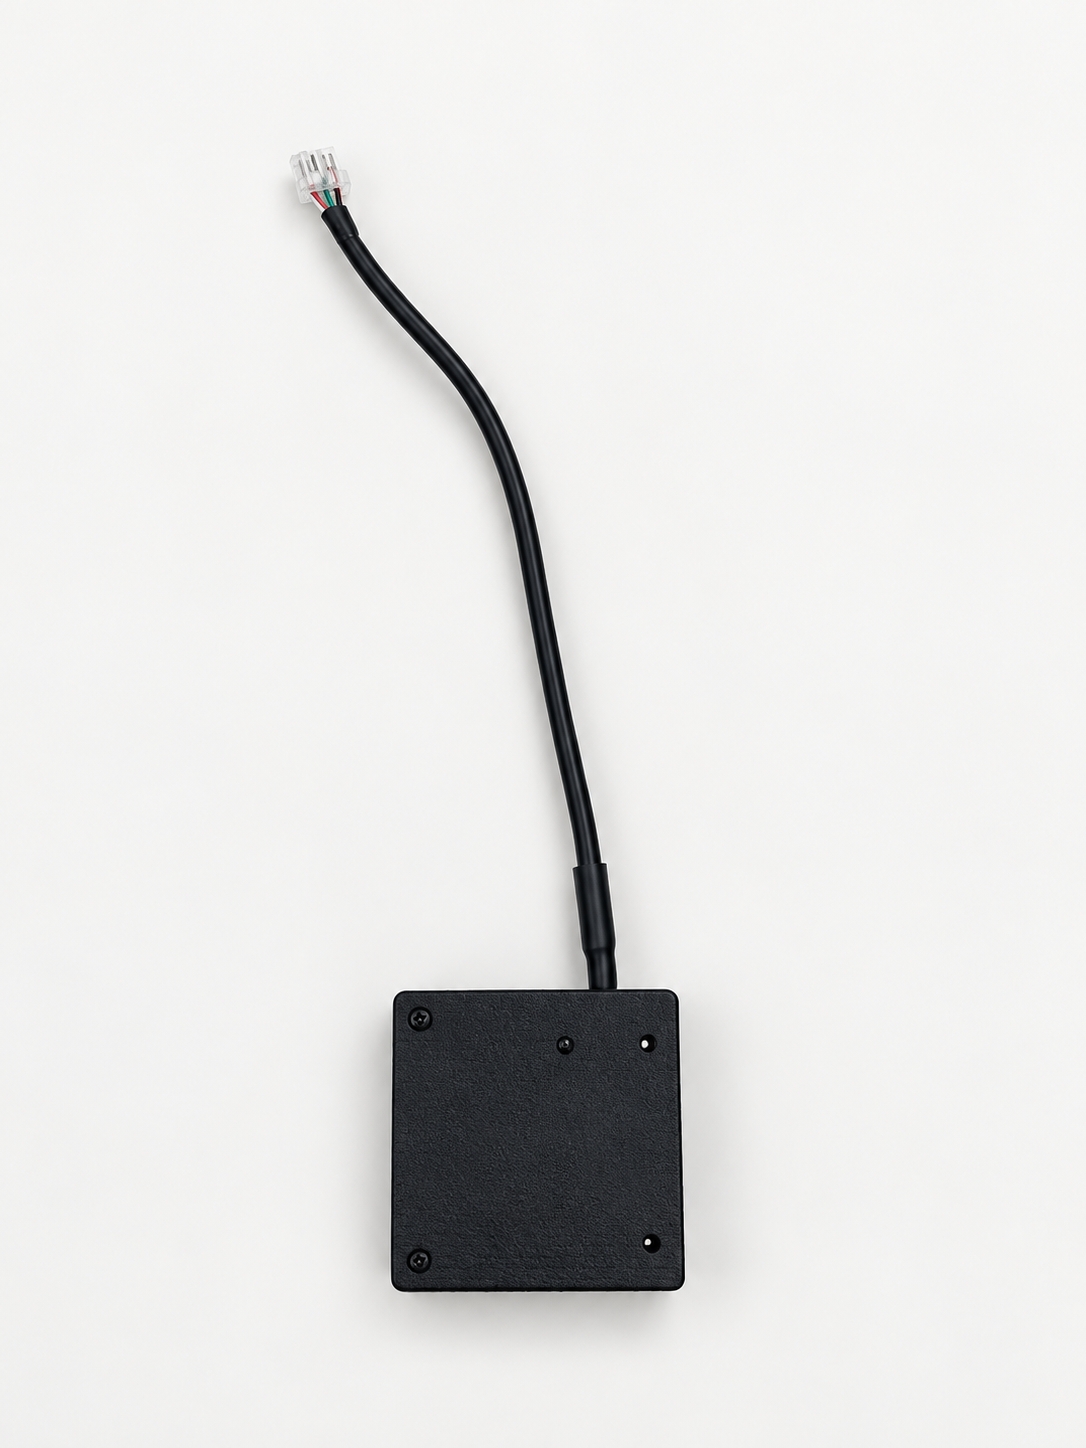
| 14 | TTL-to-USB-C module | TTL to USB-C; supports an external cable harness for power and data transmission | 2 | pc | |
| 15 | Wireless receiver | Receives data from the wireless module | 1 | pc | |
3. Key Parameters
| Category | Parameter | Specification |
|---|---|---|
| Performance | End-to-end latency | Wired <20 ms; wireless <30 ms |
| Sensor sampling rate | 120 Hz | |
| IMU sensor | Finger sensor type | 6DOF inertial sensor |
| Gyroscope range | ±4000 dps | |
| Accelerometer range | ±8 g | |
| EMF sensor | Number of EMF modules | 5 EMF receiver modules as standard |
| Wireless module | Power and battery life | Power consumption 1.7 W; battery life greater than 3 h |
| Weight | 65 g | |
| Dimensions | 44.7 × 63.3 × 28 mm | |
| Communication range | 10 m | |
| Spatial tracking | Position accuracy | 2 mm |
| Orientation accuracy | 3 deg | |
| Electrical | Power input | Powered through the Hub USB-C port |
| Voltage | 4.6~5.5 V | |
| Current | 300 mA | |
| Communication | Wired communication | CAN FD or UART; UART supports conversion to RS-485, RS-232, RS-422, or USB |
| Hardware dimensions | Fingertip module | 12.6 × 22.85 × 7.7 mm |
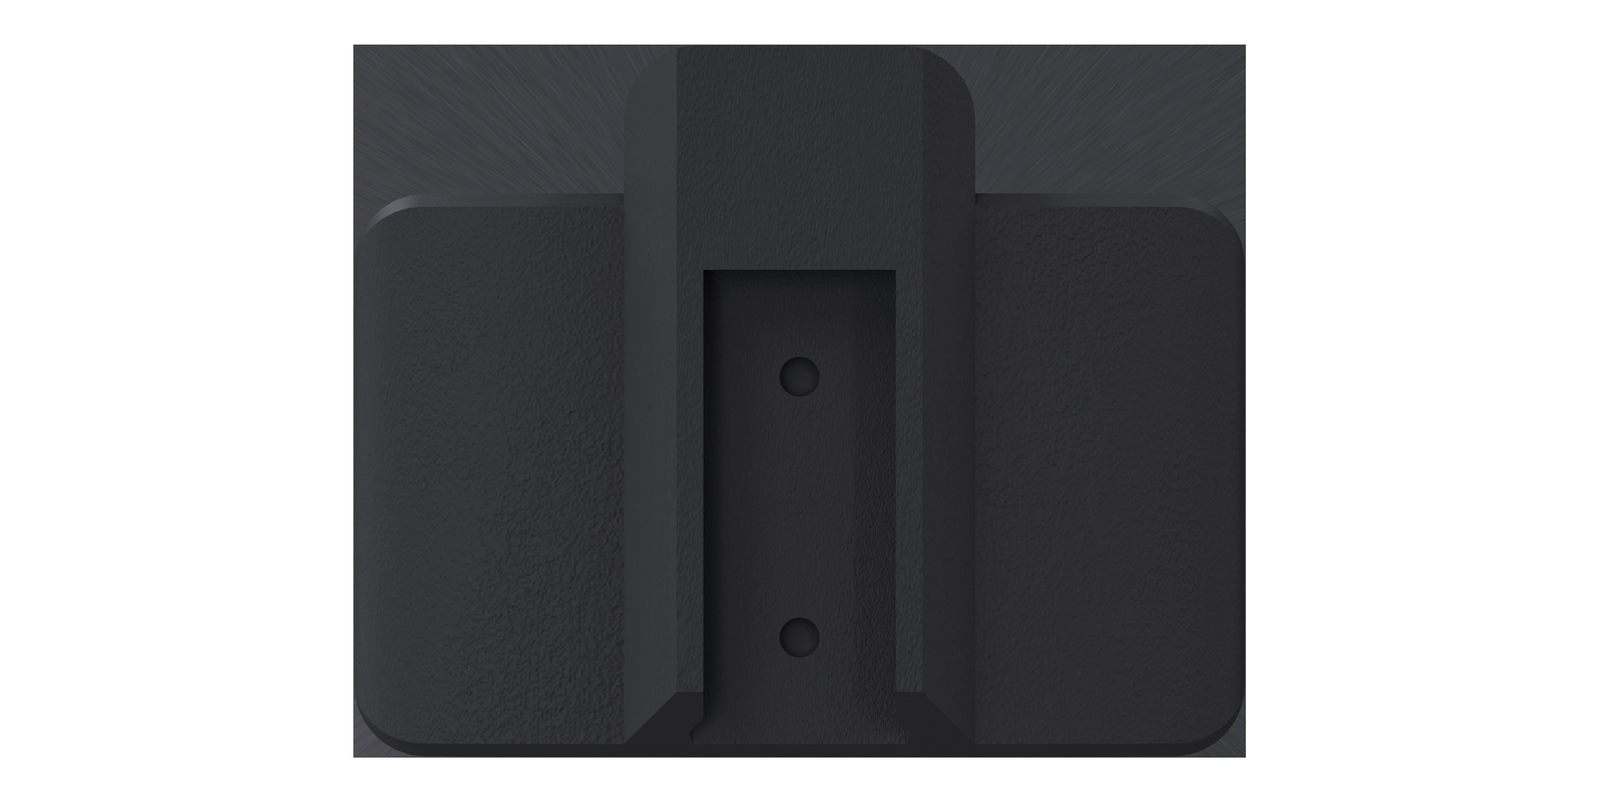
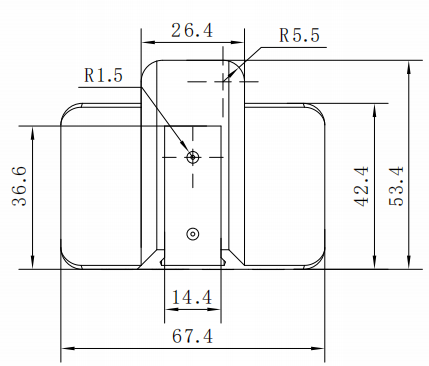
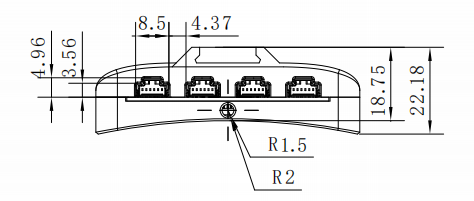
| Dorsal controller | 67.4 × 53.4 × 22.2 mm | |
| Environment | Operating temperature | 0~40 ℃ |
| Operating humidity | 20%~80% | |
| Fit | Textile glove sizes | M, L, XL (standard: L) |
| Product weight | One glove | 115 g ± 5 g |
4. Dimensions
4.1 Glove Dimensions
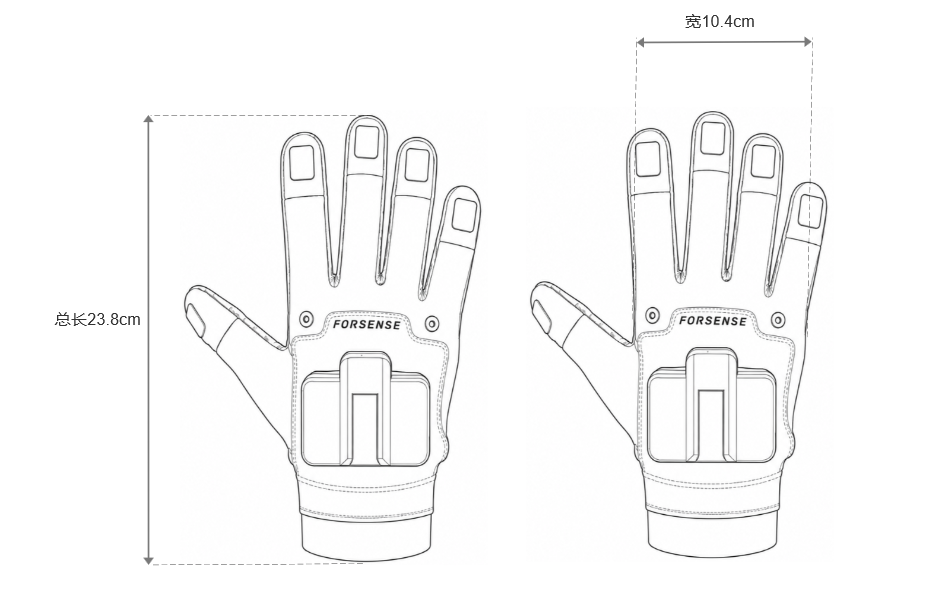
| Size | Hand length | Palm circumference |
|---|---|---|
| M | 17.5~18.9 cm | 18.5~20.5 cm |
| L | 18.9~20.2 cm | 20.0~22.5 cm |
| XL | 20.2~21.6 cm | 22.0~24.5 cm |
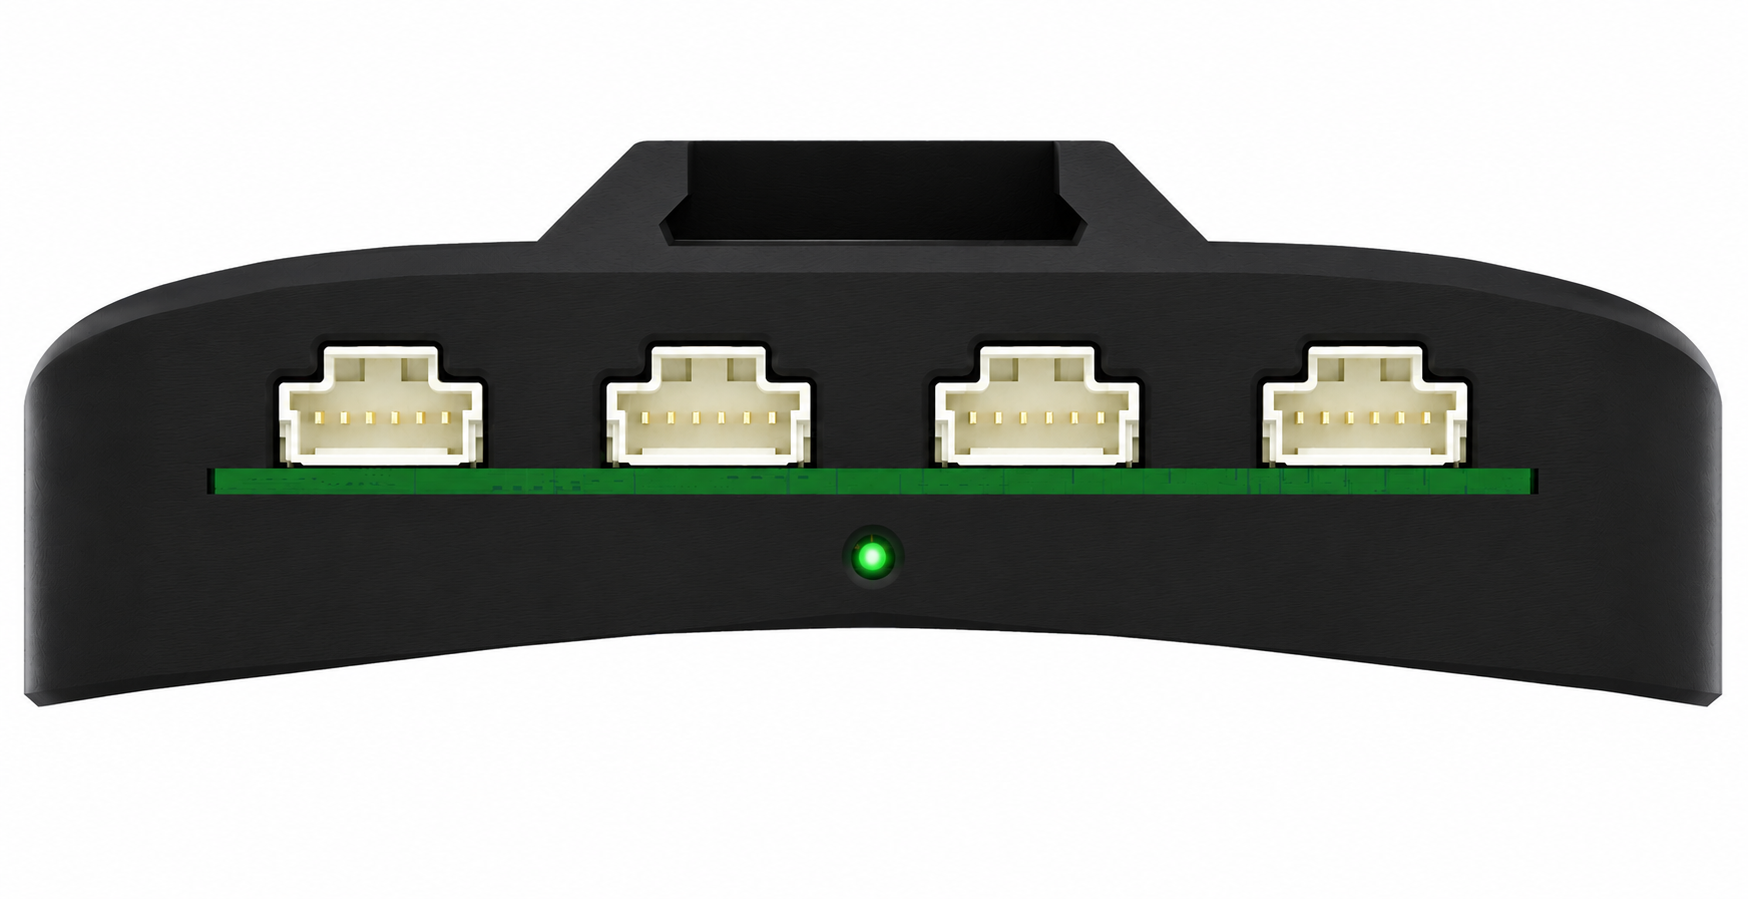
4.2 Dorsal Controller Dimensions
5. Interfaces and LED States
5.1 Interface Pinout
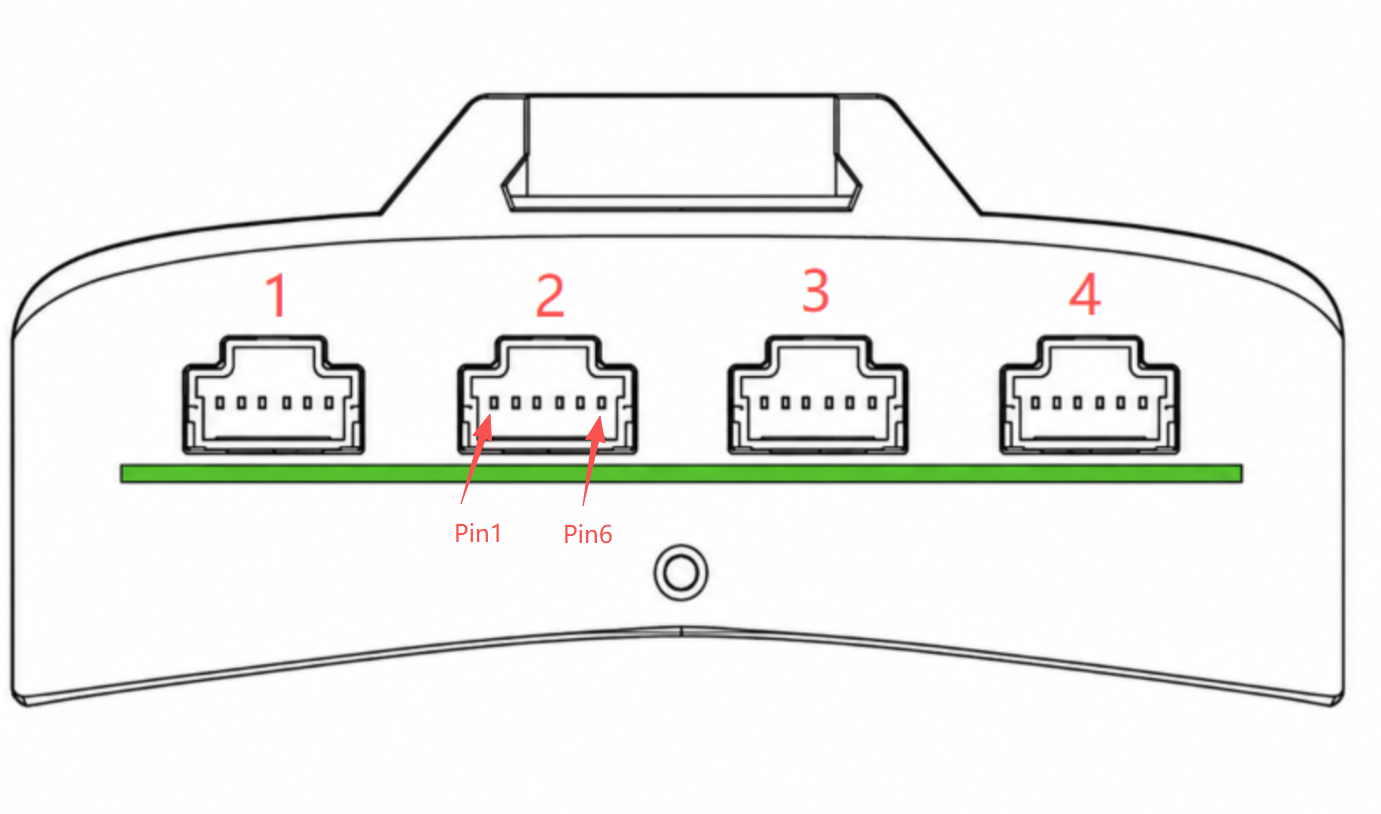
| Port | Pin1 | Pin2 | Pin3 | Pin4 | Pin5 | Pin6 | Use |
|---|---|---|---|---|---|---|---|
| Port 1 (CAN) | DC5V | GPIO1 | GPIO2 | CAN_L | CAN_H | GND | CAN bus device connection |
| Port 2 (UART1) | DC5V | GPIO1 | GPIO2 | TX1 | RX1 | GND | UART1 device connection |
| Port 3 (UART2) | DC5V | GPIO1 | GPIO2 | TX2 | RX2 | GND | UART2 device connection |
| Port 4 (UART3) | DC5V | GPIO1 | GPIO2 | TX3 | RX3 | GND | UART3 device connection |
5.2 LED States
| Priority | Category | System state | LED color | Pattern |
|---|---|---|---|---|
| 1 (highest) | Upgrade | Firmware upgrade in progress | Blue | Fast flashing |
| 2 | Fault | Hardware fault | Red | Steady |
| 3 | Fault | Critical warning fault | Red | Slow flashing |
| 4 | Fault | General warning fault | Red | Fast flashing |
| 5 | Initialization | Startup initialization in progress | Blue | Slow flashing |
| 6 | Operating | Magnetic interference avoidance is active, left/right synchronization is valid, and both gloves operate normally | Green | Steady |
| 7 (lowest) | Operating | One glove operating normally | Blue | Steady |
6. Connection Diagram